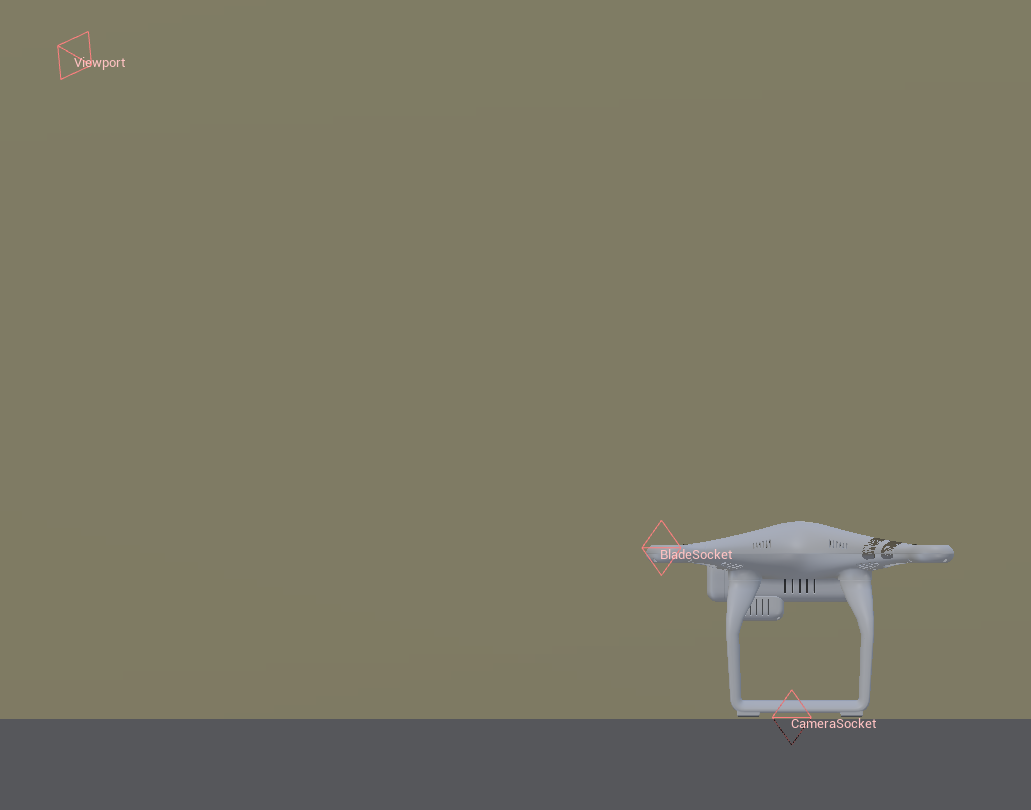
UAV Agent
Description
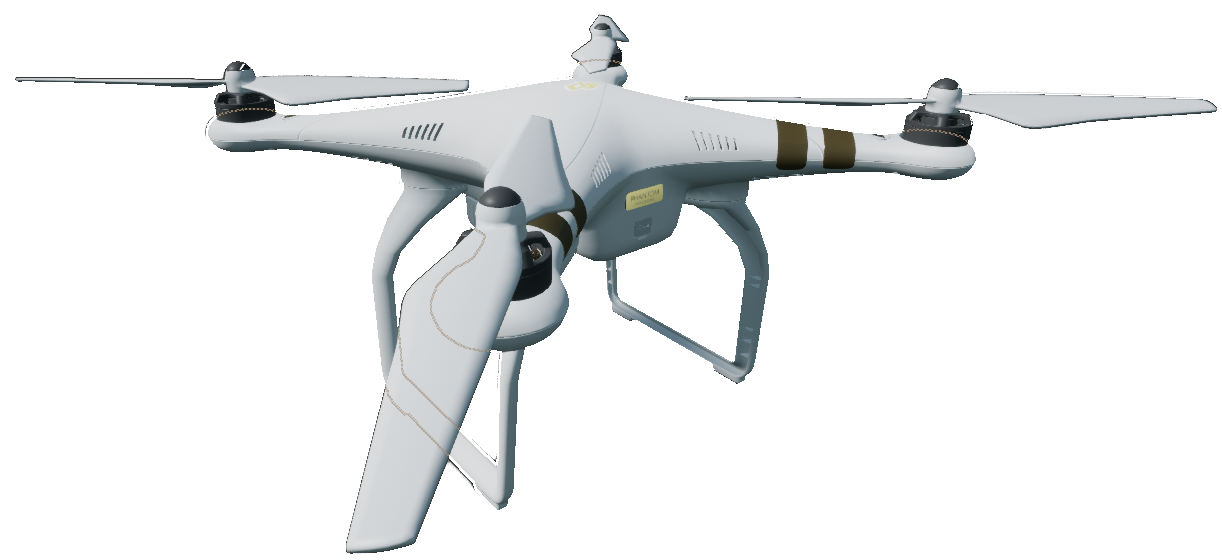
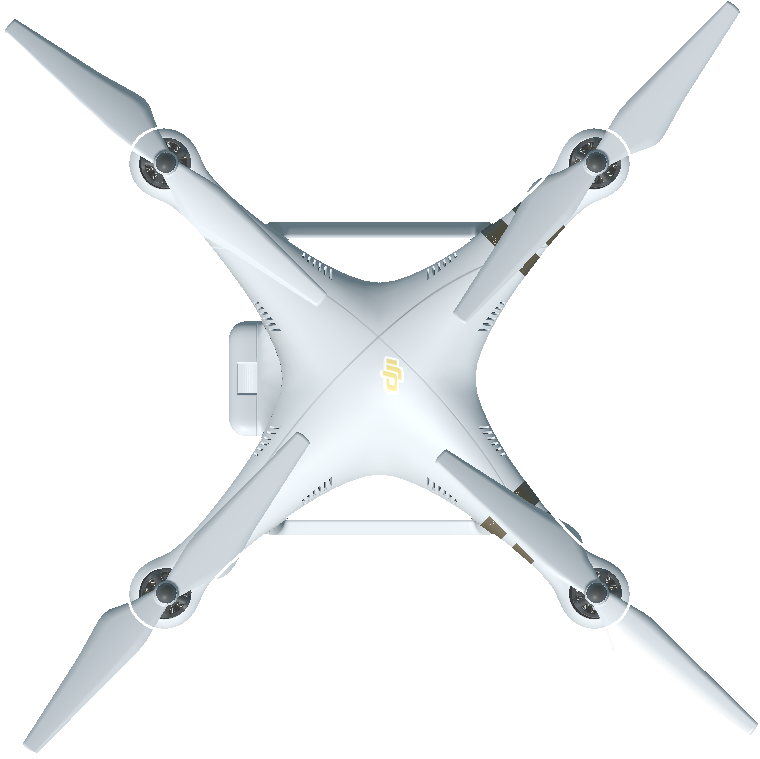
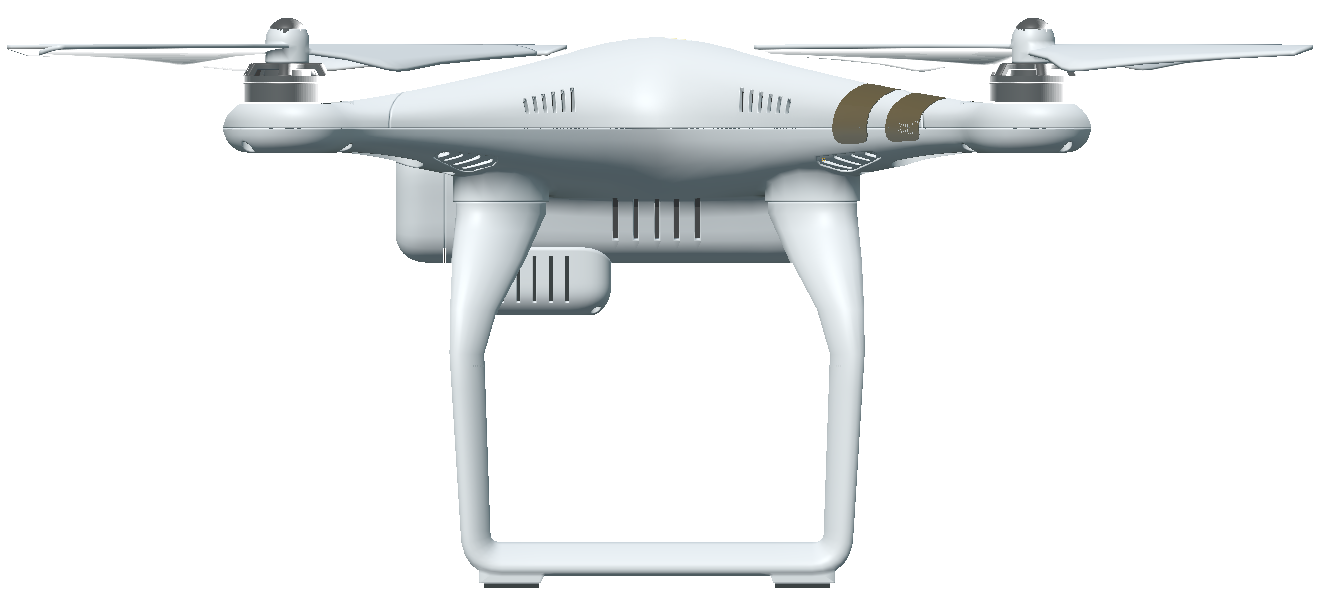
A quadcopter UAV agent.
See the UavAgent class.
Control Schemes
- UAV Torques (``0``)
A 4-length floating point vector used to specify the pitch torque, roll torque, yaw torque and thrust with indices 0, 1, 2 and 3 respectively.
- UAV Roll / Pitch / Yaw Targets(``1``)
A 4-length floating point vector used to specify the pitch, roll, yaw, and altitude targets. The values are specified in indices 0, 1, 2, and 3 respectively.
Sockets
All sockets are oriented in the agent’s body frame (right-handed NWU, with the x-axis pointing forward, the y-axis pointing to the left, and the z-axis pointing upward) unless stated otherwise. See Sensor Placement & Sockets for details.
Socket Definitions
Socket Name |
Location |
Description |
|---|---|---|
|
(0, 0, 0) |
located underneath the uav body. |
|
(-130, 0, 120) |
located behind the agent. |
Socket Frames